Use, delivery and support
Documented details refer to the stated materials and their review date. Suitability for your task and the binding delivery scope are confirmed in a specific quotation.
Suitable use
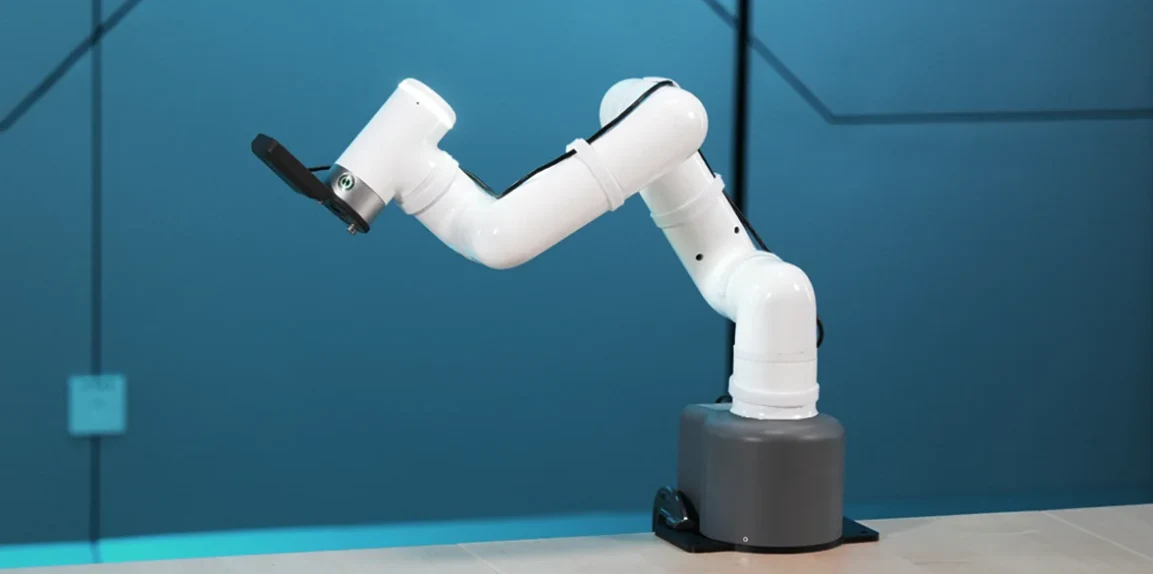
Catalogue focus and configuration: Robotic arm for education, research and light-load automation development.
Documented in source materials
- For education, experiments and light-load handling prototypes, with a documented 450 mm reach and 1 kg payload.Source review: 2026-10-24
Confirm individually
Define the task, environment, operator experience and expected outcome. Catalogue positioning alone does not establish suitability for a particular site.
Limitations
Documented in source materials
- Degrees of freedom: 6Source review: 2026-10-20
- Working radius: 450 mmSource review: 2026-10-20
- Payload: 1 kgSource review: 2026-10-20
- Repeatability: ±0.1 mmSource review: 2026-10-20
- The arm must be securely mounted and its safety functions configured. Adding a gripper or other equipment requires assessment of the complete application.Source review: 2026-10-24
Confirm individually
Check loads, workspace, safety and an acceptance test for the complete application. Specifications of one variant do not automatically apply to another.
Package contents
Catalogue focus and configuration: Optional grippers, camera flange and suction tools; select for the application.
Documented in source materials
- The manufacturer's Pro 450 standard table names a 24 V adapter, emergency stop, network cable and myGripper F100. Confirm the applicable packing list and exact gripper for the quoted configuration.Source review: 2026-10-24
Confirm individually
Confirm the packing-list revision for SKU 4020200001. The current standard table names F100, while a programming example uses F100 Pro; neither source proves the exact gripper in every supplier bundle. Request an itemized list: model and controller, power supply, batteries, tools, peripherals, licences and documentation. Photographs and compatible accessory lists do not establish package contents.
Programming
Documented in source materials
- Python control uses pymycobot's Pro450Client over the network. Gripper model, firmware and communication mode must match the selected example.Source review: 2026-10-24
Confirm individually
Confirm firmware and pymycobot versions and the selected gripper's communication mode. ROS / simulation examples require a separately configured computer and matched dependencies. Confirm SDK/API access, supported software versions, licences, control access and any MALONI development work. An available interface does not mean programming is included.
Availability
No separate detail is documented for this area.
Confirm individually
Confirm the exact variant, quantity, destination, shipping and delivery date in the quotation. A published catalogue does not establish stock availability.
Support
No separate detail is documented for this area.
Confirm individually
Agree training, contact point, remote or on-site support, service, spare parts and warranty terms. Scope, price and response times require confirmation; MALONI services and manufacturer commitments are assessed separately.
A technical team selecting a platform, arm or component for a defined process. Clarify the load, workspace and interfaces before selection.
Discuss this model’s suitability ↗Before choosing myCobot Pro 450
- Task, environment, exact configuration and required interfaces.
- Tools, peripherals, SDK/API access and supported software versions.
- Acceptance criteria, safety assessment, training and support scope.
Simulations and demonstrations support development evaluation. Suitability and safety at a real work site require an assessment of the entire application; catalogue information does not guarantee autonomy, performance or return on investment.
Discuss programming and integration →
Technical support and service →