Use, delivery and support
Documented details refer to the stated materials and their review date. Suitability for your task and the binding delivery scope are confirmed in a specific quotation.
Suitable use
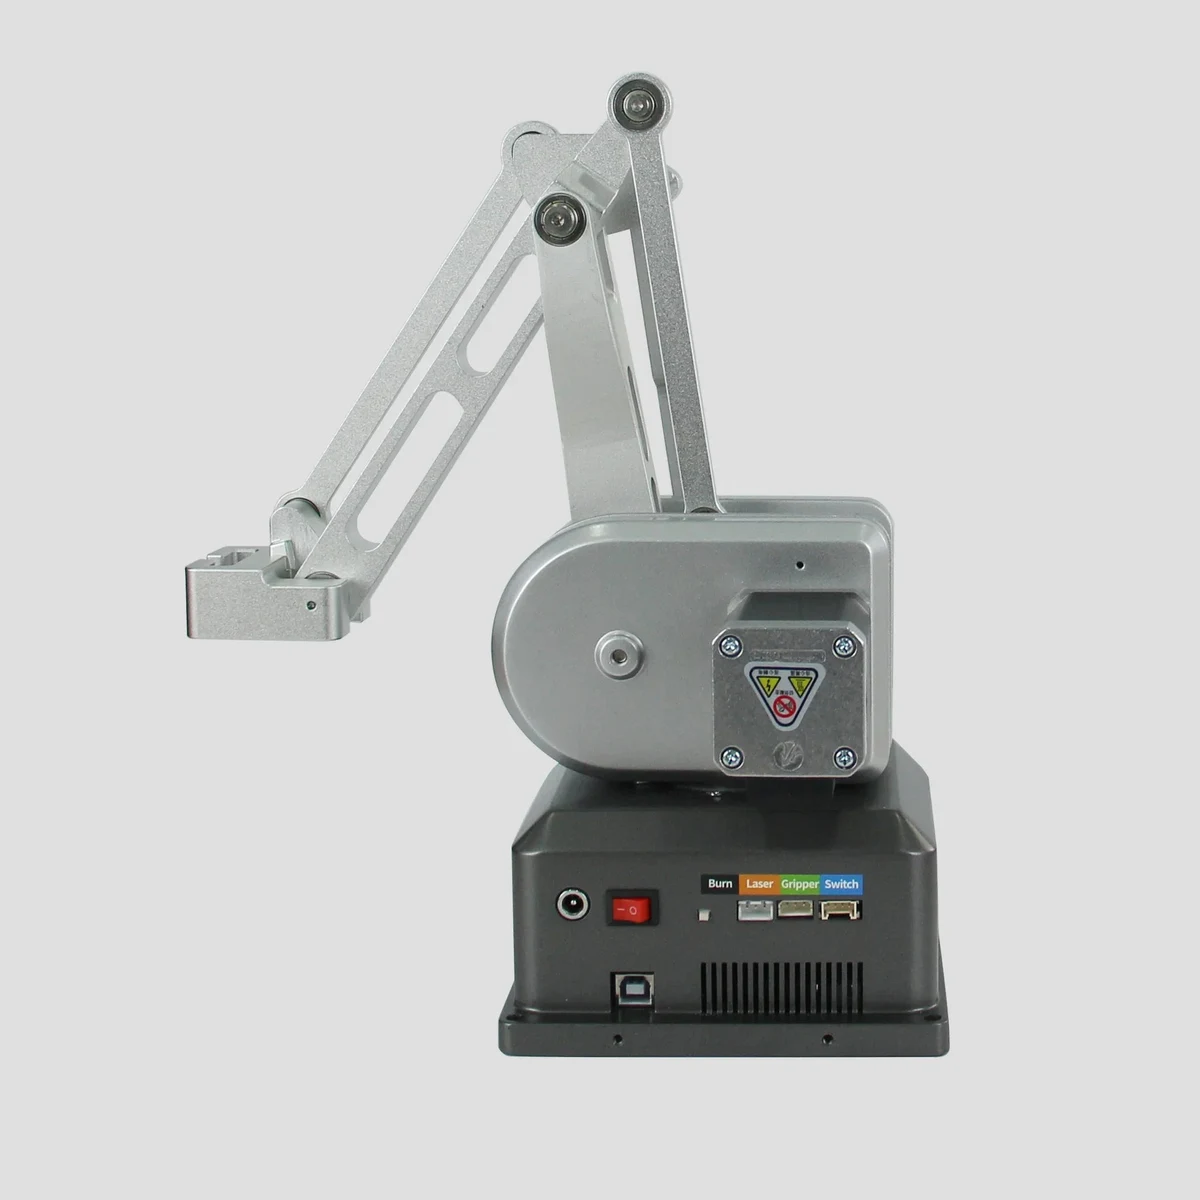
Catalogue focus and configuration: Desktop stepper-motor arm for drawing, vision-based sorting and robotics education.
Documented in source materials
- For desktop robotics teaching, drawing and vision-sorting experiments; the selected tool and kit determine the task.Source review: 2026-10-24
Confirm individually
Describe the teaching or research task, team experience, workspace and required software interfaces. Define the task, environment, operator experience and expected outcome. Catalogue positioning alone does not establish suitability for a particular site.
Limitations
Documented in source materials
- Working radius: 340 mmSource review: 2026-10-20
- Payload: 650 gSource review: 2026-10-20
- Repeatability: ±0.1 mmSource review: 2026-10-20
- Use indoors, away from water, dust and vibration. The arm needs its specified external power supply; USB is for communication.Source review: 2026-10-24
Confirm individually
Check loads, workspace, safety and an acceptance test for the complete application. Specifications of one variant do not automatically apply to another. Agree a sample task, compatible software, delivery scope and documentation for the selected configuration.
Package contents
Catalogue focus and configuration: Drawing Kit; Laser Engraving Kit; Vision Education Kit with suction or gripper; Conveyor Belt Kit 2024. Robot inclusion must be stated in each quotation.
Documented in source materials
- The manufacturer's Standard list names the arm, power adapter and USB communication cable. Drawing, laser and vision sets have separate contents; the quotation must identify the kit and whether the arm and camera are included.Source review: 2026-10-24
Confirm individually
Confirm the itemized kit and revision. The official list has no verified match to vision-kit SKUs 4010800007 / 4010800008, so inclusion of the arm and camera remains unconfirmed for those SKUs. Request an itemized list: model and controller, power supply, batteries, tools, peripherals, licences and documentation. Photographs and compatible accessory lists do not establish package contents.
Programming
Documented in source materials
- Python control is documented through pymycobot's ultraArmP340 class. Match the library and firmware to the P340 and its selected accessories.Source review: 2026-10-24
Confirm individually
For vision or conveyor examples, confirm the matched firmware, library, camera and OpenCV versions. Laser use also needs an assessment of the complete protected setup. Confirm SDK/API access, supported software versions, licences, control access and any MALONI development work. An available interface does not mean programming is included.
Availability
No separate detail is documented for this area.
Confirm individually
Confirm the exact variant, quantity, destination, shipping and delivery date in the quotation. A published catalogue does not establish stock availability.
Support
No separate detail is documented for this area.
Confirm individually
Agree training, contact point, remote or on-site support, service, spare parts and warranty terms. Scope, price and response times require confirmation; MALONI services and manufacturer commitments are assessed separately.
Schools, teaching laboratories and developers choosing a platform for programming, kinematics and robot vision.
Discuss this model’s suitability ↗Before choosing ultraArm P340
- Model, controller and exact configuration; specifications of another variant do not automatically apply.
- SDK, operating system and ROS versions supported for the intended task.
- Kit contents: the robot, tool, camera, chassis and teaching materials may be separate items.
A teaching or research demonstration does not validate a complete operational application. Confirm integration, safety, software availability and support for the specific setup.
Discuss programming and integration →
Technical support and service →