MALONI / HUMANOID INTELLIGENCE
Astribot T1
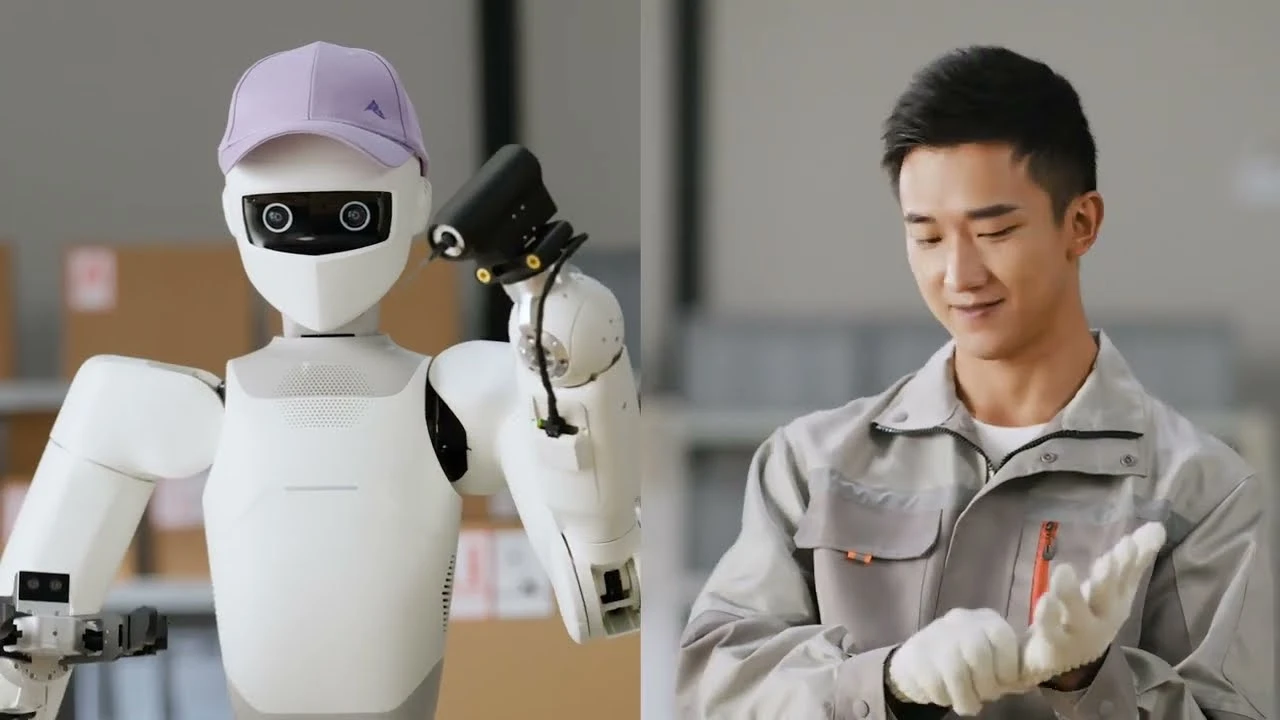
Wheeled humanoid for research, demonstrations, data collection and light-duty tasks. Intended for trained personnel on level floors in enclosed indoor environments.
Know what you are comparing
Wheeled humanoid for research, demonstrations, data collection and light-duty tasks. Intended for trained personnel on level floors in enclosed indoor environments.
MALONI represents Astribot commercially in Central Europe.
Manufacturer profileFor professional indoor use only. Excluded uses include childcare, medical care, rescue and high-risk operations. MALONI reviews conformity documents for the proposed configuration before supply.
Enquire about T1 with MALONI →Scroll horizontally to see additional robots.
| Feature | Model notesWheeled humanoid for research, demonstrations, data collection and light-duty tasks in enclosed indoor environments, operated by trained personnel. |
|---|---|
| Declared use | UNKNOWN No verified value for this configuration. |
| Load and handling method | UNKNOWN No verified value for this configuration. |
| Payload per arm at horizontal reach | UNKNOWN No verified value for this configuration. |
| Hands and optional equipment | UNKNOWN No verified value for this configuration. |
| locomotion | Wheeled baseManufacturer Claim Source & conditionsLevel indoor floors. Manufacturer demonstration. Original source & attribution · Astribot launch film, indoor demonstration Last verified: 2026-11-10. Publication date: 2026-05-26. Supporting passage: The manufacturer demonstration shows a mobile wheeled base. |
| Walking speed and conditions | UNKNOWN No verified value for this configuration. |
| Runtime and test regime | UNKNOWN No verified value for this configuration. |
| Height | UNKNOWN No verified value for this configuration. |
| Weight and included equipment | UNKNOWN No verified value for this configuration. |
| Total degrees of freedom / configuration | UNKNOWN No verified value for this configuration. |
| SDK / API and access | UNKNOWN No verified value for this configuration. |
| ROS 2 | UNKNOWN No verified value for this configuration. |
| Task-specific autonomy | UNKNOWN No verified value for this configuration. |
| Remote control / teleoperation | UNKNOWN No verified value for this configuration. |
| Hardware price | UNKNOWN No verified value for this configuration. |
| Availability and delivery | UNKNOWN No verified value for this configuration. |
| Confirmed delivery countries | UNKNOWN No verified value for this configuration. |
| EU configuration documentation | UNKNOWN No verified value for this configuration. |
| Manufacturer service and warranty | UNKNOWN No verified value for this configuration. |
| Dimensions and axis order | UNKNOWN No verified value for this configuration. |
| Folded dimensions | UNKNOWN No verified value for this configuration. |
| Single-arm degrees of freedom | UNKNOWN No verified value for this configuration. |
| Single-leg degrees of freedom | UNKNOWN No verified value for this configuration. |
| Waist degrees of freedom | UNKNOWN No verified value for this configuration. |
| Head degrees of freedom | UNKNOWN No verified value for this configuration. |
| Arm reach / span as defined by manufacturer | UNKNOWN No verified value for this configuration. |
| Peak torque and applicable joint | UNKNOWN No verified value for this configuration. |
| Joint motion range | UNKNOWN No verified value for this configuration. |
| Arm positioning repeatability | UNKNOWN No verified value for this configuration. |
| Battery capacity in stated units | UNKNOWN No verified value for this configuration. |
| Battery replacement / hot swap | UNKNOWN No verified value for this configuration. |
| Charging time | UNKNOWN No verified value for this configuration. |
| Power supply and charger | UNKNOWN No verified value for this configuration. |
| Operating environment | UNKNOWN No verified value for this configuration. |
| Ingress protection and scope | UNKNOWN No verified value for this configuration. |
| Cameras and spatial sensors | UNKNOWN No verified value for this configuration. |
| Tactile and force sensing | UNKNOWN No verified value for this configuration. |
| Microphones and speakers | UNKNOWN No verified value for this configuration. |
| Standard and optional computing | UNKNOWN No verified value for this configuration. |
| Operating / development system | UNKNOWN No verified value for this configuration. |
| Data interfaces | UNKNOWN No verified value for this configuration. |
| Wireless connectivity | UNKNOWN No verified value for this configuration. |
| Custom motion programming | UNKNOWN No verified value for this configuration. |
| Simulation and models | UNKNOWN No verified value for this configuration. |
| Delivered functions / custom development | UNKNOWN No verified value for this configuration. |
| Degrees of freedom per arm | UNKNOWN No verified value for this configuration. |
| actuation | Cable-drivenManufacturer Claim Source & conditionsManufacturer description of T1. Original source & attribution · Astribot press release, T1 introduction Last verified: 2026-11-10. Publication date: 2026-09-29. Supporting passage: Cable-driven transmission |
© Astribot · Source & license Model notes
Wheeled humanoid for research, demonstrations, data collection and light-duty tasks in enclosed indoor environments, operated by trained personnel.
Declared use
- Astribot T1
- UNKNOWN No verified value for this configuration.
Load and handling method
- Astribot T1
- UNKNOWN No verified value for this configuration.
Payload per arm at horizontal reach
- Astribot T1
- UNKNOWN No verified value for this configuration.
Hands and optional equipment
- Astribot T1
- UNKNOWN No verified value for this configuration.
locomotion
- Astribot T1
- Wheeled baseManufacturer Claim
Source & conditions
Level indoor floors. Manufacturer demonstration.
Original source & attribution · Astribot launch film, indoor demonstration
Last verified: 2026-11-10. Publication date: 2026-05-26.
Supporting passage: The manufacturer demonstration shows a mobile wheeled base.
Walking speed and conditions
- Astribot T1
- UNKNOWN No verified value for this configuration.
Runtime and test regime
- Astribot T1
- UNKNOWN No verified value for this configuration.
Height
- Astribot T1
- UNKNOWN No verified value for this configuration.
Weight and included equipment
- Astribot T1
- UNKNOWN No verified value for this configuration.
Total degrees of freedom / configuration
- Astribot T1
- UNKNOWN No verified value for this configuration.
SDK / API and access
- Astribot T1
- UNKNOWN No verified value for this configuration.
ROS 2
- Astribot T1
- UNKNOWN No verified value for this configuration.
Task-specific autonomy
- Astribot T1
- UNKNOWN No verified value for this configuration.
Remote control / teleoperation
- Astribot T1
- UNKNOWN No verified value for this configuration.
Hardware price
- Astribot T1
- UNKNOWN No verified value for this configuration.
Availability and delivery
- Astribot T1
- UNKNOWN No verified value for this configuration.
Confirmed delivery countries
- Astribot T1
- UNKNOWN No verified value for this configuration.
EU configuration documentation
- Astribot T1
- UNKNOWN No verified value for this configuration.
Manufacturer service and warranty
- Astribot T1
- UNKNOWN No verified value for this configuration.
Dimensions and axis order
- Astribot T1
- UNKNOWN No verified value for this configuration.
Folded dimensions
- Astribot T1
- UNKNOWN No verified value for this configuration.
Single-arm degrees of freedom
- Astribot T1
- UNKNOWN No verified value for this configuration.
Single-leg degrees of freedom
- Astribot T1
- UNKNOWN No verified value for this configuration.
Waist degrees of freedom
- Astribot T1
- UNKNOWN No verified value for this configuration.
Head degrees of freedom
- Astribot T1
- UNKNOWN No verified value for this configuration.
Arm reach / span as defined by manufacturer
- Astribot T1
- UNKNOWN No verified value for this configuration.
Peak torque and applicable joint
- Astribot T1
- UNKNOWN No verified value for this configuration.
Joint motion range
- Astribot T1
- UNKNOWN No verified value for this configuration.
Arm positioning repeatability
- Astribot T1
- UNKNOWN No verified value for this configuration.
Battery capacity in stated units
- Astribot T1
- UNKNOWN No verified value for this configuration.
Battery replacement / hot swap
- Astribot T1
- UNKNOWN No verified value for this configuration.
Charging time
- Astribot T1
- UNKNOWN No verified value for this configuration.
Power supply and charger
- Astribot T1
- UNKNOWN No verified value for this configuration.
Operating environment
- Astribot T1
- UNKNOWN No verified value for this configuration.
Ingress protection and scope
- Astribot T1
- UNKNOWN No verified value for this configuration.
Cameras and spatial sensors
- Astribot T1
- UNKNOWN No verified value for this configuration.
Tactile and force sensing
- Astribot T1
- UNKNOWN No verified value for this configuration.
Microphones and speakers
- Astribot T1
- UNKNOWN No verified value for this configuration.
Standard and optional computing
- Astribot T1
- UNKNOWN No verified value for this configuration.
Operating / development system
- Astribot T1
- UNKNOWN No verified value for this configuration.
Data interfaces
- Astribot T1
- UNKNOWN No verified value for this configuration.
Wireless connectivity
- Astribot T1
- UNKNOWN No verified value for this configuration.
Custom motion programming
- Astribot T1
- UNKNOWN No verified value for this configuration.
Simulation and models
- Astribot T1
- UNKNOWN No verified value for this configuration.
Delivered functions / custom development
- Astribot T1
- UNKNOWN No verified value for this configuration.
Degrees of freedom per arm
- Astribot T1
- UNKNOWN No verified value for this configuration.
actuation
- Astribot T1
- Cable-drivenManufacturer Claim
Source & conditions
Manufacturer description of T1.
Original source & attribution · Astribot press release, T1 introduction
Last verified: 2026-11-10. Publication date: 2026-09-29.
Supporting passage: Cable-driven transmission
MALONI deployment assessment
MALONI Robotics editorial team
Start with the documented capabilities and configuration notes above. Check task fit, local availability and the specific software and service terms before proposing a pilot.
Check your requirements · Scoring methodologyReviews and discussion
Read community experience, ask a question or write a review
Ownership and integration badges require evidence. Every contribution is moderated before publication.
Public deployment references
No deployment reference has completed editorial review for this profile.
A demonstration, a pilot and a paid deployment describe different levels of evidence. Manufacturer announcements remain labelled as such.
From your brief to a validated solution
Clarify the brief
Review the task, environment, configuration and expected outcome. Identify what still needs verification.
Technical assessment or pilot
Agree the scope, price, deliverables and acceptance test before a paid assessment or pilot. Distinguish simulation from physical validation.
Supply, programming and integration
The subsequent quote specifies the configuration, work, timeline and support terms for the country of use.
Catalogue specifications do not confirm the outcome of your application. Scope and pricing are agreed individually.
Technical analysis: G1 object transfer in simulation · Technical analysis: transfer in ROS 2 and Gazebo
Manufacturer prices are reference prices. MALONI confirms its quote and delivery for each destination. Coverage is growing and is not a complete global census. Unknowns remain visible. Manufacturer statements are separate from independent measurements. Read the methodology.