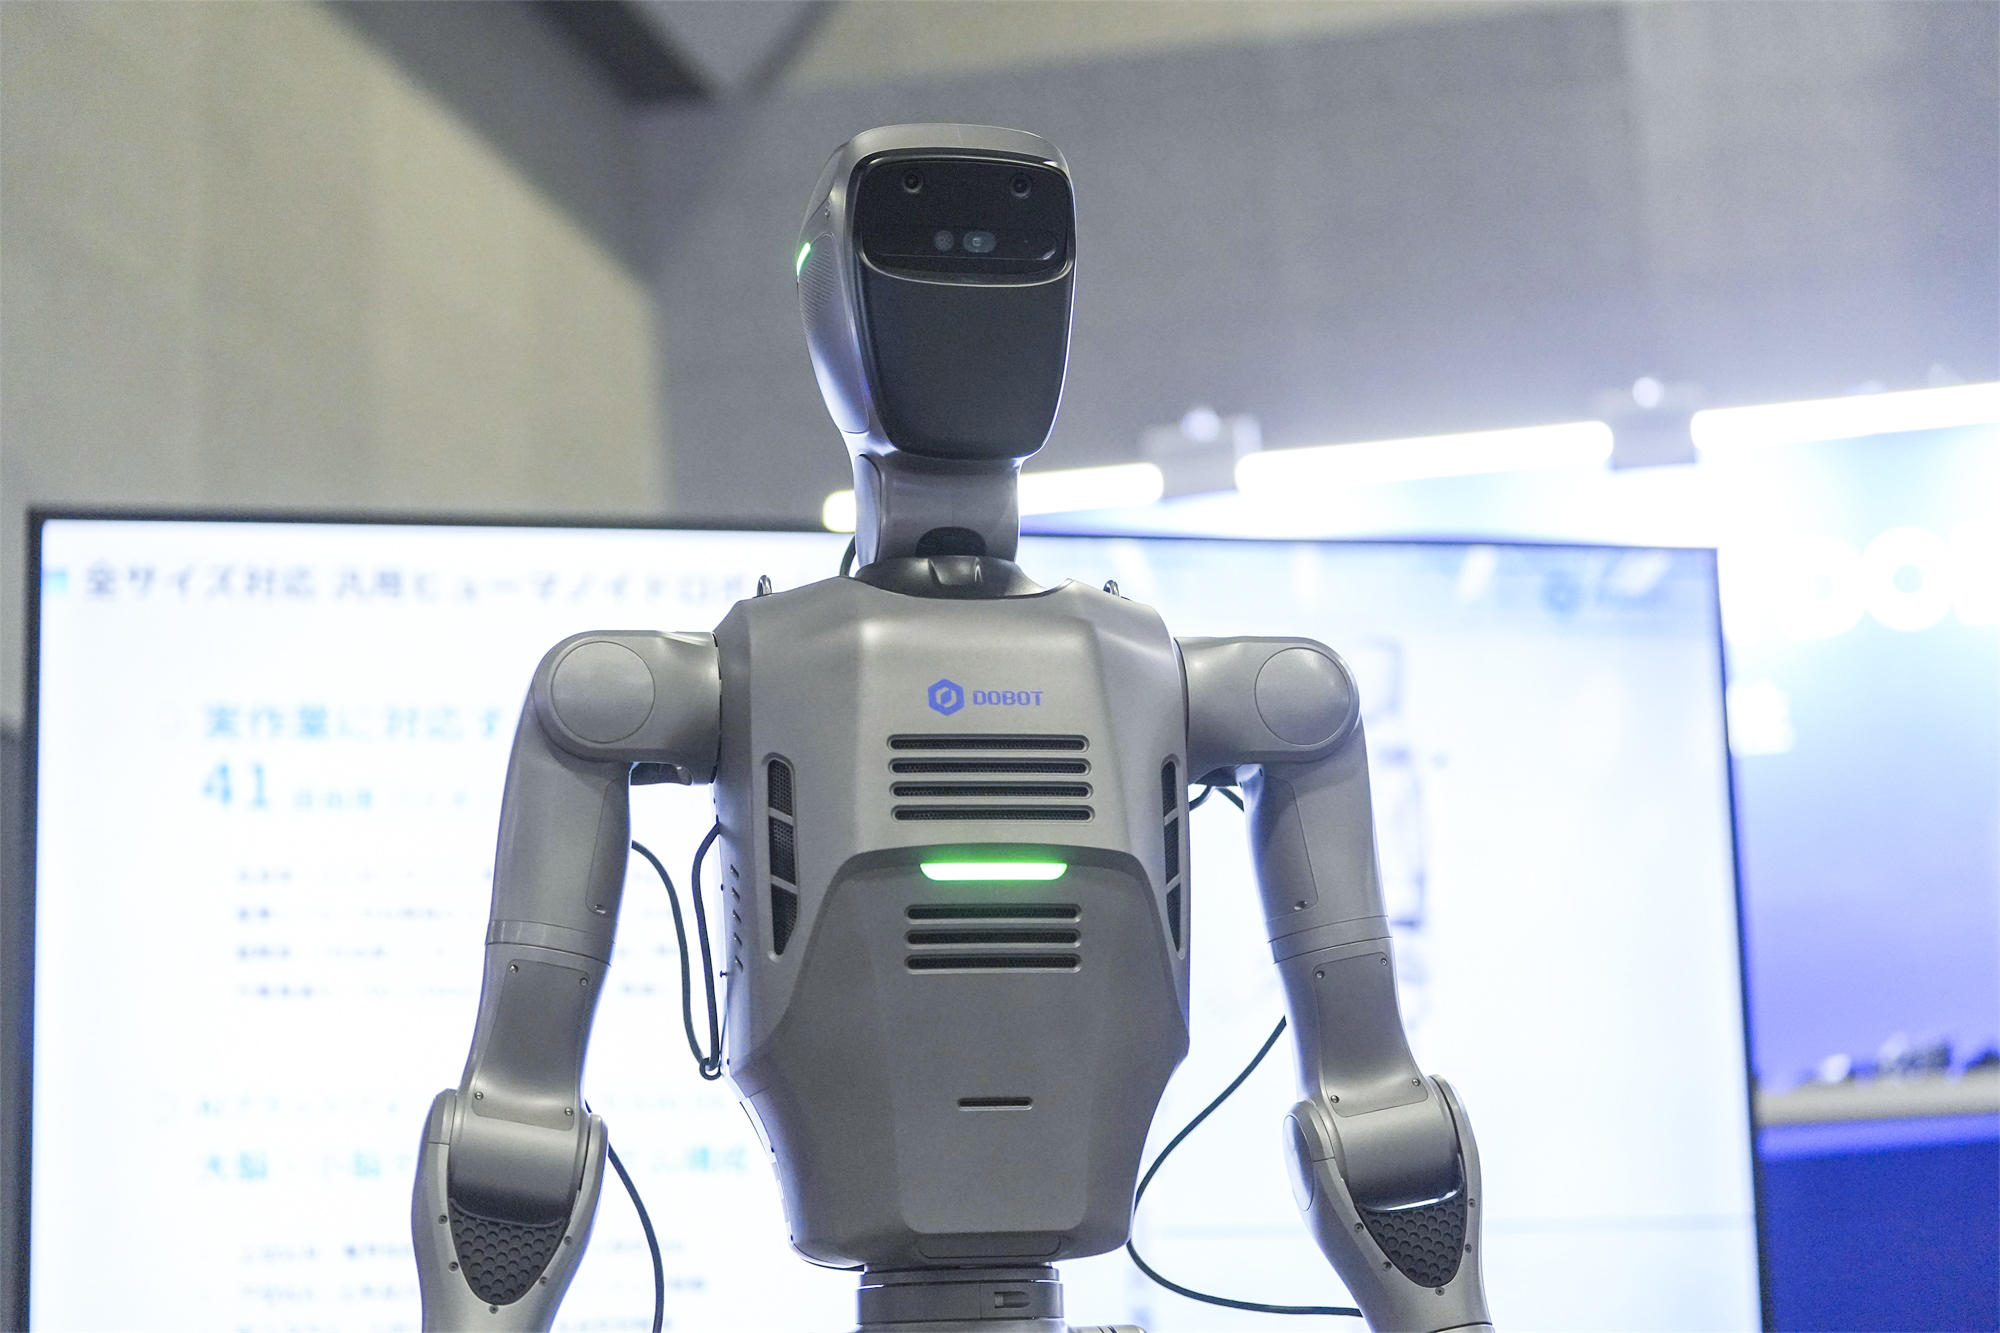
Planning a pilot? Start with the documented use, handling limits, software access and delivery. Review the operating conditions before choosing a configuration.
Scope of the manufacturer’s published configuration. Confirm the actual delivery package.
Declared use
Research and industrial applicationsManufacturer ClaimSource & conditions
Manufacturer specification, not a MALONI measurement. Confirm revision and delivery contents.
Original source & attribution · Manufacturer-authored manual hosted by RobotShop; printed pp. 2–3 and 24, Max column. Not an independent reseller measurement. Local PDF hash retained; no public rehosting permission asserted.
Last verified: 2026-10-21. Publication date: UNKNOWN.
Legacy reviewed record (2026-10-21); original source passage requires re-extraction.
Load and handling method
3.5 kgManufacturer ClaimSource & conditions
Single arm without dexterous hand / gripper; tool mass is not useful payload.
Original source & attribution · Manufacturer-authored manual hosted by RobotShop; printed pp. 2–3 and 24, Max column. Not an independent reseller measurement. Local PDF hash retained; no public rehosting permission asserted.
Last verified: 2026-10-21. Publication date: UNKNOWN.
Legacy reviewed record (2026-10-21); original source passage requires re-extraction.
Last verified: 2026-10-21. Publication date: UNKNOWN.
Legacy reviewed record (2026-10-21); original source passage requires re-extraction.
locomotion
UNKNOWN No verified value for this configuration.
Walking speed and conditions
1.5 m/sManufacturer ClaimSource & conditions
Manufacturer maximum walking speed; surface and load not stated.
Original source & attribution · Manufacturer-authored manual hosted by RobotShop; printed pp. 2–3 and 24, Max column. Not an independent reseller measurement. Local PDF hash retained; no public rehosting permission asserted.
Last verified: 2026-10-21. Publication date: UNKNOWN.
Legacy reviewed record (2026-10-21); original source passage requires re-extraction.
Runtime and test regime
≈2 hManufacturer ClaimSource & conditions
Measurement regime and load not stated.
Original source & attribution · Manufacturer-authored manual hosted by RobotShop; printed pp. 2–3 and 24, Max column. Not an independent reseller measurement. Local PDF hash retained; no public rehosting permission asserted.
Last verified: 2026-10-21. Publication date: UNKNOWN.
Legacy reviewed record (2026-10-21); original source passage requires re-extraction.
Height
≈1650 mmManufacturer ClaimSource & conditions
Manufacturer specification, not a MALONI measurement. Confirm revision and delivery contents.
Original source & attribution · Manufacturer-authored manual hosted by RobotShop; printed pp. 2–3 and 24, Max column. Not an independent reseller measurement. Local PDF hash retained; no public rehosting permission asserted.
Last verified: 2026-10-21. Publication date: UNKNOWN.
Legacy reviewed record (2026-10-21); original source passage requires re-extraction.
Weight and included equipment
≈58 kg in brochure / ≈62 kg in SDK guideConflicting sourcesSource & conditions
Confirm hardware revision, battery and end-effector basis before choosing a weight.
Last verified: 2026-10-21. Publication date: UNKNOWN.
Legacy reviewed record (2026-10-21); original source passage requires re-extraction.
SDK / API and access
C++ SDK, DDS and RPC; PC2 developmentManufacturer ClaimSource & conditions
Manufacturer specification, not a MALONI measurement. Confirm revision and delivery contents.
Original source & attribution · Manufacturer-authored manual hosted by RobotShop; printed pp. 2–3 and 24, Max column. Not an independent reseller measurement. Local PDF hash retained; no public rehosting permission asserted.
Last verified: 2026-10-21. Publication date: UNKNOWN.
Legacy reviewed record (2026-10-21); original source passage requires re-extraction.
ROS 2
Official dobot_atom_ros2 package named in Max manualManufacturer ClaimSource & conditions
Verify revision, dependencies and interfaces for the actual delivery.
Original source & attribution · Manufacturer-authored manual hosted by RobotShop; printed pp. 2–3 and 24, Max column. Not an independent reseller measurement. Local PDF hash retained; no public rehosting permission asserted.
Last verified: 2026-10-21. Publication date: UNKNOWN.
Legacy reviewed record (2026-10-21); original source passage requires re-extraction.
Task-specific autonomy
UNKNOWN No verified value for this configuration.
Remote control / teleoperation
VR/MR, whole-body or segmentedManufacturer ClaimSource & conditions
Last verified: 2026-10-21. Publication date: UNKNOWN.
Legacy reviewed record (2026-10-21); original source passage requires re-extraction.
Hardware price
UNKNOWN No verified value for this configuration.
Availability and delivery
UNKNOWN No verified value for this configuration.
Confirmed delivery countries
UNKNOWN No verified value for this configuration.
EU configuration documentation
UNKNOWN No verified value for this configuration.
Manufacturer service and warranty
Manufacturer lists 1-year warranty; confirm terms of the specific saleManufacturer ClaimSource & conditions
Manufacturer specification, not a MALONI measurement. Confirm revision and delivery contents.
Original source & attribution · Manufacturer-authored manual hosted by RobotShop; printed pp. 2–3 and 24, Max column. Not an independent reseller measurement. Local PDF hash retained; no public rehosting permission asserted.
Last verified: 2026-10-21. Publication date: UNKNOWN.
Legacy reviewed record (2026-10-21); original source passage requires re-extraction.
Dimensions and axis order
Height ≈1650 mm; width/depth not statedManufacturer ClaimSource & conditions
Manufacturer specification, not a MALONI measurement. Confirm revision and delivery contents.
Original source & attribution · Manufacturer-authored manual hosted by RobotShop; printed pp. 2–3 and 24, Max column. Not an independent reseller measurement. Local PDF hash retained; no public rehosting permission asserted.
Last verified: 2026-10-21. Publication date: UNKNOWN.
Legacy reviewed record (2026-10-21); original source passage requires re-extraction.
Folded dimensions
UNKNOWN No verified value for this configuration.
Single-arm degrees of freedom
7Manufacturer ClaimSource & conditions
Manufacturer specification, not a MALONI measurement. Confirm revision and delivery contents.
Original source & attribution · Manufacturer-authored manual hosted by RobotShop; printed pp. 2–3 and 24, Max column. Not an independent reseller measurement. Local PDF hash retained; no public rehosting permission asserted.
Last verified: 2026-10-21. Publication date: UNKNOWN.
Legacy reviewed record (2026-10-21); original source passage requires re-extraction.
Single-leg degrees of freedom
6Manufacturer ClaimSource & conditions
Manufacturer specification, not a MALONI measurement. Confirm revision and delivery contents.
Original source & attribution · Manufacturer-authored manual hosted by RobotShop; printed pp. 2–3 and 24, Max column. Not an independent reseller measurement. Local PDF hash retained; no public rehosting permission asserted.
Last verified: 2026-10-21. Publication date: UNKNOWN.
Legacy reviewed record (2026-10-21); original source passage requires re-extraction.
Waist degrees of freedom
1Manufacturer ClaimSource & conditions
Manufacturer specification, not a MALONI measurement. Confirm revision and delivery contents.
Original source & attribution · Manufacturer-authored manual hosted by RobotShop; printed pp. 2–3 and 24, Max column. Not an independent reseller measurement. Local PDF hash retained; no public rehosting permission asserted.
Last verified: 2026-10-21. Publication date: UNKNOWN.
Legacy reviewed record (2026-10-21); original source passage requires re-extraction.
Head degrees of freedom
2Manufacturer ClaimSource & conditions
Manufacturer specification, not a MALONI measurement. Confirm revision and delivery contents.
Original source & attribution · Manufacturer-authored manual hosted by RobotShop; printed pp. 2–3 and 24, Max column. Not an independent reseller measurement. Local PDF hash retained; no public rehosting permission asserted.
Last verified: 2026-10-21. Publication date: UNKNOWN.
Legacy reviewed record (2026-10-21); original source passage requires re-extraction.
Arm reach / span as defined by manufacturer
600 mmManufacturer ClaimSource & conditions
One arm without dexterous hand / gripper.
Original source & attribution · Manufacturer-authored manual hosted by RobotShop; printed pp. 2–3 and 24, Max column. Not an independent reseller measurement. Local PDF hash retained; no public rehosting permission asserted.
Last verified: 2026-10-21. Publication date: UNKNOWN.
Legacy reviewed record (2026-10-21); original source passage requires re-extraction.
Peak torque and applicable joint
UNKNOWN No verified value for this configuration.
Joint motion range
UNKNOWN No verified value for this configuration.
Arm positioning repeatability
±0.05 mmManufacturer ClaimSource & conditions
Single-arm repeated positioning, not whole-robot accuracy while moving.
Original source & attribution · Manufacturer-authored manual hosted by RobotShop; printed pp. 2–3 and 24, Max column. Not an independent reseller measurement. Local PDF hash retained; no public rehosting permission asserted.
Last verified: 2026-10-21. Publication date: UNKNOWN.
Legacy reviewed record (2026-10-21); original source passage requires re-extraction.
Battery capacity in stated units
15 AhManufacturer ClaimSource & conditions
Manufacturer specification, not a MALONI measurement. Confirm revision and delivery contents.
Original source & attribution · Manufacturer-authored brochure hosted by Funduino; Max table p. 1. Weight 58 kg and charging ≈1 h differ from earlier SDK guide 62 kg / ≈2 h. Hand prose 12 DoF is ambiguous; table says 6 DoF × 2.
Last verified: 2026-10-21. Publication date: UNKNOWN.
Legacy reviewed record (2026-10-21); original source passage requires re-extraction.
Battery replacement / hot swap
Quick replaceable; live hot swap not establishedManufacturer ClaimSource & conditions
Manufacturer specification, not a MALONI measurement. Confirm revision and delivery contents.
Original source & attribution · Manufacturer-authored brochure hosted by Funduino; Max table p. 1. Weight 58 kg and charging ≈1 h differ from earlier SDK guide 62 kg / ≈2 h. Hand prose 12 DoF is ambiguous; table says 6 DoF × 2.
Last verified: 2026-10-21. Publication date: UNKNOWN.
Legacy reviewed record (2026-10-21); original source passage requires re-extraction.
Charging time
≈1 h in brochure / ≈2 h in SDK guideConflicting sourcesSource & conditions
Charging protocol and exact hardware revision require confirmation.
Manufacturer specification, not a MALONI measurement. Confirm revision and delivery contents.
Original source & attribution · Manufacturer-authored manual hosted by RobotShop; printed pp. 2–3 and 24, Max column. Not an independent reseller measurement. Local PDF hash retained; no public rehosting permission asserted.
Last verified: 2026-10-21. Publication date: UNKNOWN.
Legacy reviewed record (2026-10-21); original source passage requires re-extraction.
Manufacturer specification, not a MALONI measurement. Confirm revision and delivery contents.
Original source & attribution · Manufacturer-authored manual hosted by RobotShop; printed pp. 2–3 and 24, Max column. Not an independent reseller measurement. Local PDF hash retained; no public rehosting permission asserted.
Last verified: 2026-10-21. Publication date: UNKNOWN.
Legacy reviewed record (2026-10-21); original source passage requires re-extraction.
FP32 TFLOPS and TOPS are different metrics. PC1 is not open to custom development.
Original source & attribution · Manufacturer-authored manual hosted by RobotShop; printed pp. 2–3 and 24, Max column. Not an independent reseller measurement. Local PDF hash retained; no public rehosting permission asserted.
Last verified: 2026-10-21. Publication date: UNKNOWN.
Legacy reviewed record (2026-10-21); original source passage requires re-extraction.
Recommended PC2 development environment; not Windows/macOS support.
Original source & attribution · Manufacturer-authored manual hosted by RobotShop; printed pp. 2–3 and 24, Max column. Not an independent reseller measurement. Local PDF hash retained; no public rehosting permission asserted.
Last verified: 2026-10-21. Publication date: UNKNOWN.
Legacy reviewed record (2026-10-21); original source passage requires re-extraction.
Data interfaces
DDS / RPCManufacturer ClaimSource & conditions
Manufacturer specification, not a MALONI measurement. Confirm revision and delivery contents.
Original source & attribution · Manufacturer-authored manual hosted by RobotShop; printed pp. 2–3 and 24, Max column. Not an independent reseller measurement. Local PDF hash retained; no public rehosting permission asserted.
Last verified: 2026-10-21. Publication date: UNKNOWN.
Legacy reviewed record (2026-10-21); original source passage requires re-extraction.
Wireless connectivity
UNKNOWN No verified value for this configuration.
Custom motion programming
trueManufacturer ClaimSource & conditions
Development on PC2; PC1 runs manufacturer services and is not open.
Original source & attribution · Manufacturer-authored manual hosted by RobotShop; printed pp. 2–3 and 24, Max column. Not an independent reseller measurement. Local PDF hash retained; no public rehosting permission asserted.
Last verified: 2026-10-21. Publication date: UNKNOWN.
Legacy reviewed record (2026-10-21); original source passage requires re-extraction.
Simulation and models
Optional set: URDF and training frameworkManufacturer ClaimSource & conditions
Confirm ordered kit contents and compatible simulator.
Scope of the manufacturer’s published configuration. Confirm the actual delivery package.
Declared use
DOBOT ATOM Max
Research and industrial applicationsManufacturer ClaimSource & conditions
Manufacturer specification, not a MALONI measurement. Confirm revision and delivery contents.
Original source & attribution · Manufacturer-authored manual hosted by RobotShop; printed pp. 2–3 and 24, Max column. Not an independent reseller measurement. Local PDF hash retained; no public rehosting permission asserted.
Last verified: 2026-10-21. Publication date: UNKNOWN.
Legacy reviewed record (2026-10-21); original source passage requires re-extraction.
Load and handling method
DOBOT ATOM Max
3.5 kgManufacturer ClaimSource & conditions
Single arm without dexterous hand / gripper; tool mass is not useful payload.
Original source & attribution · Manufacturer-authored manual hosted by RobotShop; printed pp. 2–3 and 24, Max column. Not an independent reseller measurement. Local PDF hash retained; no public rehosting permission asserted.
Last verified: 2026-10-21. Publication date: UNKNOWN.
Legacy reviewed record (2026-10-21); original source passage requires re-extraction.
Last verified: 2026-10-21. Publication date: UNKNOWN.
Legacy reviewed record (2026-10-21); original source passage requires re-extraction.
locomotion
DOBOT ATOM Max
UNKNOWN No verified value for this configuration.
Walking speed and conditions
DOBOT ATOM Max
1.5 m/sManufacturer ClaimSource & conditions
Manufacturer maximum walking speed; surface and load not stated.
Original source & attribution · Manufacturer-authored manual hosted by RobotShop; printed pp. 2–3 and 24, Max column. Not an independent reseller measurement. Local PDF hash retained; no public rehosting permission asserted.
Last verified: 2026-10-21. Publication date: UNKNOWN.
Legacy reviewed record (2026-10-21); original source passage requires re-extraction.
Runtime and test regime
DOBOT ATOM Max
≈2 hManufacturer ClaimSource & conditions
Measurement regime and load not stated.
Original source & attribution · Manufacturer-authored manual hosted by RobotShop; printed pp. 2–3 and 24, Max column. Not an independent reseller measurement. Local PDF hash retained; no public rehosting permission asserted.
Last verified: 2026-10-21. Publication date: UNKNOWN.
Legacy reviewed record (2026-10-21); original source passage requires re-extraction.
Height
DOBOT ATOM Max
≈1650 mmManufacturer ClaimSource & conditions
Manufacturer specification, not a MALONI measurement. Confirm revision and delivery contents.
Original source & attribution · Manufacturer-authored manual hosted by RobotShop; printed pp. 2–3 and 24, Max column. Not an independent reseller measurement. Local PDF hash retained; no public rehosting permission asserted.
Last verified: 2026-10-21. Publication date: UNKNOWN.
Legacy reviewed record (2026-10-21); original source passage requires re-extraction.
Weight and included equipment
DOBOT ATOM Max
≈58 kg in brochure / ≈62 kg in SDK guideConflicting sourcesSource & conditions
Confirm hardware revision, battery and end-effector basis before choosing a weight.
Last verified: 2026-10-21. Publication date: UNKNOWN.
Legacy reviewed record (2026-10-21); original source passage requires re-extraction.
SDK / API and access
DOBOT ATOM Max
C++ SDK, DDS and RPC; PC2 developmentManufacturer ClaimSource & conditions
Manufacturer specification, not a MALONI measurement. Confirm revision and delivery contents.
Original source & attribution · Manufacturer-authored manual hosted by RobotShop; printed pp. 2–3 and 24, Max column. Not an independent reseller measurement. Local PDF hash retained; no public rehosting permission asserted.
Last verified: 2026-10-21. Publication date: UNKNOWN.
Legacy reviewed record (2026-10-21); original source passage requires re-extraction.
ROS 2
DOBOT ATOM Max
Official dobot_atom_ros2 package named in Max manualManufacturer ClaimSource & conditions
Verify revision, dependencies and interfaces for the actual delivery.
Original source & attribution · Manufacturer-authored manual hosted by RobotShop; printed pp. 2–3 and 24, Max column. Not an independent reseller measurement. Local PDF hash retained; no public rehosting permission asserted.
Last verified: 2026-10-21. Publication date: UNKNOWN.
Legacy reviewed record (2026-10-21); original source passage requires re-extraction.
Task-specific autonomy
DOBOT ATOM Max
UNKNOWN No verified value for this configuration.
Remote control / teleoperation
DOBOT ATOM Max
VR/MR, whole-body or segmentedManufacturer ClaimSource & conditions
Last verified: 2026-10-21. Publication date: UNKNOWN.
Legacy reviewed record (2026-10-21); original source passage requires re-extraction.
Hardware price
DOBOT ATOM Max
UNKNOWN No verified value for this configuration.
Availability and delivery
DOBOT ATOM Max
UNKNOWN No verified value for this configuration.
Confirmed delivery countries
DOBOT ATOM Max
UNKNOWN No verified value for this configuration.
EU configuration documentation
DOBOT ATOM Max
UNKNOWN No verified value for this configuration.
Manufacturer service and warranty
DOBOT ATOM Max
Manufacturer lists 1-year warranty; confirm terms of the specific saleManufacturer ClaimSource & conditions
Manufacturer specification, not a MALONI measurement. Confirm revision and delivery contents.
Original source & attribution · Manufacturer-authored manual hosted by RobotShop; printed pp. 2–3 and 24, Max column. Not an independent reseller measurement. Local PDF hash retained; no public rehosting permission asserted.
Last verified: 2026-10-21. Publication date: UNKNOWN.
Legacy reviewed record (2026-10-21); original source passage requires re-extraction.
Dimensions and axis order
DOBOT ATOM Max
Height ≈1650 mm; width/depth not statedManufacturer ClaimSource & conditions
Manufacturer specification, not a MALONI measurement. Confirm revision and delivery contents.
Original source & attribution · Manufacturer-authored manual hosted by RobotShop; printed pp. 2–3 and 24, Max column. Not an independent reseller measurement. Local PDF hash retained; no public rehosting permission asserted.
Last verified: 2026-10-21. Publication date: UNKNOWN.
Legacy reviewed record (2026-10-21); original source passage requires re-extraction.
Folded dimensions
DOBOT ATOM Max
UNKNOWN No verified value for this configuration.
Single-arm degrees of freedom
DOBOT ATOM Max
7Manufacturer ClaimSource & conditions
Manufacturer specification, not a MALONI measurement. Confirm revision and delivery contents.
Original source & attribution · Manufacturer-authored manual hosted by RobotShop; printed pp. 2–3 and 24, Max column. Not an independent reseller measurement. Local PDF hash retained; no public rehosting permission asserted.
Last verified: 2026-10-21. Publication date: UNKNOWN.
Legacy reviewed record (2026-10-21); original source passage requires re-extraction.
Single-leg degrees of freedom
DOBOT ATOM Max
6Manufacturer ClaimSource & conditions
Manufacturer specification, not a MALONI measurement. Confirm revision and delivery contents.
Original source & attribution · Manufacturer-authored manual hosted by RobotShop; printed pp. 2–3 and 24, Max column. Not an independent reseller measurement. Local PDF hash retained; no public rehosting permission asserted.
Last verified: 2026-10-21. Publication date: UNKNOWN.
Legacy reviewed record (2026-10-21); original source passage requires re-extraction.
Waist degrees of freedom
DOBOT ATOM Max
1Manufacturer ClaimSource & conditions
Manufacturer specification, not a MALONI measurement. Confirm revision and delivery contents.
Original source & attribution · Manufacturer-authored manual hosted by RobotShop; printed pp. 2–3 and 24, Max column. Not an independent reseller measurement. Local PDF hash retained; no public rehosting permission asserted.
Last verified: 2026-10-21. Publication date: UNKNOWN.
Legacy reviewed record (2026-10-21); original source passage requires re-extraction.
Head degrees of freedom
DOBOT ATOM Max
2Manufacturer ClaimSource & conditions
Manufacturer specification, not a MALONI measurement. Confirm revision and delivery contents.
Original source & attribution · Manufacturer-authored manual hosted by RobotShop; printed pp. 2–3 and 24, Max column. Not an independent reseller measurement. Local PDF hash retained; no public rehosting permission asserted.
Last verified: 2026-10-21. Publication date: UNKNOWN.
Legacy reviewed record (2026-10-21); original source passage requires re-extraction.
Arm reach / span as defined by manufacturer
DOBOT ATOM Max
600 mmManufacturer ClaimSource & conditions
One arm without dexterous hand / gripper.
Original source & attribution · Manufacturer-authored manual hosted by RobotShop; printed pp. 2–3 and 24, Max column. Not an independent reseller measurement. Local PDF hash retained; no public rehosting permission asserted.
Last verified: 2026-10-21. Publication date: UNKNOWN.
Legacy reviewed record (2026-10-21); original source passage requires re-extraction.
Peak torque and applicable joint
DOBOT ATOM Max
UNKNOWN No verified value for this configuration.
Joint motion range
DOBOT ATOM Max
UNKNOWN No verified value for this configuration.
Arm positioning repeatability
DOBOT ATOM Max
±0.05 mmManufacturer ClaimSource & conditions
Single-arm repeated positioning, not whole-robot accuracy while moving.
Original source & attribution · Manufacturer-authored manual hosted by RobotShop; printed pp. 2–3 and 24, Max column. Not an independent reseller measurement. Local PDF hash retained; no public rehosting permission asserted.
Last verified: 2026-10-21. Publication date: UNKNOWN.
Legacy reviewed record (2026-10-21); original source passage requires re-extraction.
Battery capacity in stated units
DOBOT ATOM Max
15 AhManufacturer ClaimSource & conditions
Manufacturer specification, not a MALONI measurement. Confirm revision and delivery contents.
Original source & attribution · Manufacturer-authored brochure hosted by Funduino; Max table p. 1. Weight 58 kg and charging ≈1 h differ from earlier SDK guide 62 kg / ≈2 h. Hand prose 12 DoF is ambiguous; table says 6 DoF × 2.
Last verified: 2026-10-21. Publication date: UNKNOWN.
Legacy reviewed record (2026-10-21); original source passage requires re-extraction.
Battery replacement / hot swap
DOBOT ATOM Max
Quick replaceable; live hot swap not establishedManufacturer ClaimSource & conditions
Manufacturer specification, not a MALONI measurement. Confirm revision and delivery contents.
Original source & attribution · Manufacturer-authored brochure hosted by Funduino; Max table p. 1. Weight 58 kg and charging ≈1 h differ from earlier SDK guide 62 kg / ≈2 h. Hand prose 12 DoF is ambiguous; table says 6 DoF × 2.
Last verified: 2026-10-21. Publication date: UNKNOWN.
Legacy reviewed record (2026-10-21); original source passage requires re-extraction.
Charging time
DOBOT ATOM Max
≈1 h in brochure / ≈2 h in SDK guideConflicting sourcesSource & conditions
Charging protocol and exact hardware revision require confirmation.
Manufacturer specification, not a MALONI measurement. Confirm revision and delivery contents.
Original source & attribution · Manufacturer-authored manual hosted by RobotShop; printed pp. 2–3 and 24, Max column. Not an independent reseller measurement. Local PDF hash retained; no public rehosting permission asserted.
Last verified: 2026-10-21. Publication date: UNKNOWN.
Legacy reviewed record (2026-10-21); original source passage requires re-extraction.
Manufacturer specification, not a MALONI measurement. Confirm revision and delivery contents.
Original source & attribution · Manufacturer-authored manual hosted by RobotShop; printed pp. 2–3 and 24, Max column. Not an independent reseller measurement. Local PDF hash retained; no public rehosting permission asserted.
Last verified: 2026-10-21. Publication date: UNKNOWN.
Legacy reviewed record (2026-10-21); original source passage requires re-extraction.
FP32 TFLOPS and TOPS are different metrics. PC1 is not open to custom development.
Original source & attribution · Manufacturer-authored manual hosted by RobotShop; printed pp. 2–3 and 24, Max column. Not an independent reseller measurement. Local PDF hash retained; no public rehosting permission asserted.
Last verified: 2026-10-21. Publication date: UNKNOWN.
Legacy reviewed record (2026-10-21); original source passage requires re-extraction.
Recommended PC2 development environment; not Windows/macOS support.
Original source & attribution · Manufacturer-authored manual hosted by RobotShop; printed pp. 2–3 and 24, Max column. Not an independent reseller measurement. Local PDF hash retained; no public rehosting permission asserted.
Last verified: 2026-10-21. Publication date: UNKNOWN.
Legacy reviewed record (2026-10-21); original source passage requires re-extraction.
Data interfaces
DOBOT ATOM Max
DDS / RPCManufacturer ClaimSource & conditions
Manufacturer specification, not a MALONI measurement. Confirm revision and delivery contents.
Original source & attribution · Manufacturer-authored manual hosted by RobotShop; printed pp. 2–3 and 24, Max column. Not an independent reseller measurement. Local PDF hash retained; no public rehosting permission asserted.
Last verified: 2026-10-21. Publication date: UNKNOWN.
Legacy reviewed record (2026-10-21); original source passage requires re-extraction.
Wireless connectivity
DOBOT ATOM Max
UNKNOWN No verified value for this configuration.
Custom motion programming
DOBOT ATOM Max
trueManufacturer ClaimSource & conditions
Development on PC2; PC1 runs manufacturer services and is not open.
Original source & attribution · Manufacturer-authored manual hosted by RobotShop; printed pp. 2–3 and 24, Max column. Not an independent reseller measurement. Local PDF hash retained; no public rehosting permission asserted.
Last verified: 2026-10-21. Publication date: UNKNOWN.
Legacy reviewed record (2026-10-21); original source passage requires re-extraction.
Simulation and models
DOBOT ATOM Max
Optional set: URDF and training frameworkManufacturer ClaimSource & conditions
Confirm ordered kit contents and compatible simulator.
Last verified: 2026-10-21. Publication date: UNKNOWN.
Legacy reviewed record (2026-10-21); original source passage requires re-extraction.
Delivered functions / custom development
DOBOT ATOM Max
UNKNOWN No verified value for this configuration.
Degrees of freedom per arm
DOBOT ATOM Max
UNKNOWN No verified value for this configuration.
actuation
DOBOT ATOM Max
UNKNOWN No verified value for this configuration.
MALONI deployment assessment
MALONI Robotics editorial team
Start with the documented capabilities and configuration notes above. Check task fit, local availability and the specific software and service terms before proposing a pilot.
Manufacturer prices are reference prices. MALONI confirms its quote and delivery for each destination. Coverage is growing and is not a complete global census. Unknowns remain visible. Manufacturer statements are separate from independent measurements. Read the methodology.